Here is my environment.
- Ubuntu 16.04 with ROS Kinetic.
- Autoware.AI Ver.1.10.0 in the docker.
- LG SVL Simulator 2019.01 and 2018.12-rc1
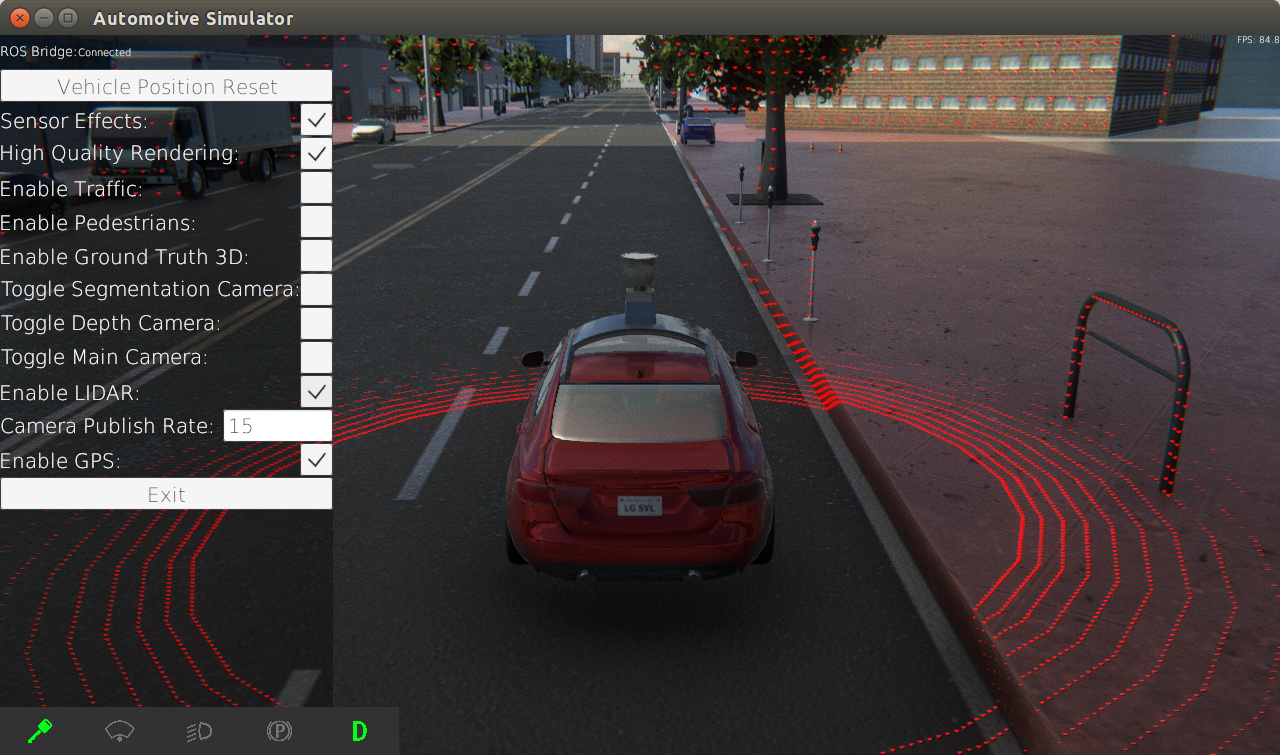
Here are my configurations of LG SVL Simulator.

Here are the screenshots of RQt.


But there are nothing in the RViz, I can’t use Autoware to control the simulator.

I wonder to get some help. Thank you very much. I am looking forward to hearing from you soon.
Mouri.