# New ROS 2 Features for Mini Pupper 2
**URL:** https://discourse.openrobotics.org/t/new-ros-2-features-for-mini-pupper-2/50806
**Category:** ROS General
**Tags:** release, ros2
**Created:** [November 3, 2025, 9:44pm UTC](https://discourse.openrobotics.org/t/new-ros-2-features-for-mini-pupper-2/50806 "2025-11-03T21:44:13Z")
**Posts on this page:** 7
**Page:** 1
### Author:  [@kishan-grewal](https://discourse.openrobotics.org/u/kishan-grewal)
#### Post date: [November 3, 2025, 9:44pm UTC](https://discourse.openrobotics.org/t/new-ros-2-features-for-mini-pupper-2/50806/1 "2025-11-03T21:44:14Z")
## New ROS 2 Features - Mini Pupper 2
Hello everyone,
I’m Kishan Grewal, a Robotics and AI student at University College London (UCL). Over the summer, I interned at MangDang in Hong Kong, where I extended the ROS 2 software stack for the Mini Pupper 2 quadruped robot.
My work broadened the Mini Pupper 2’s ROS 2 ecosystem with additional packages that work across different hardware configurations. Depending on your setup, you can now explore person tracking, autonomous navigation, or multi-robot coordination - all through ROS 2.
### Vision-Based Tracking
I developed a tracking node that performs real-time person detection and tracking using a YOLO11n ONNX model with multi-object detection and IMU feedback for stable control.
If you have a Mini Pupper 2 with a compatible Pi camera, this package lets the robot visually follow a person while maintaining orientation. The system includes a lightweight Flask web interface and RViz visualization.
[Demo - Vision Tracking](https://youtu.be/_WW_2NER2gI)
[Code - mini\_pupper\_tracking package](https://github.com/mangdangroboticsclub/mini_pupper_ros/tree/ros2-dev/mini_pupper_tracking)
### Multi-Robot Fleet Coordination
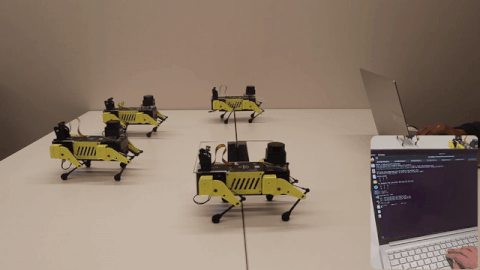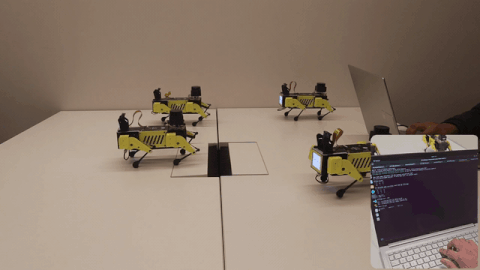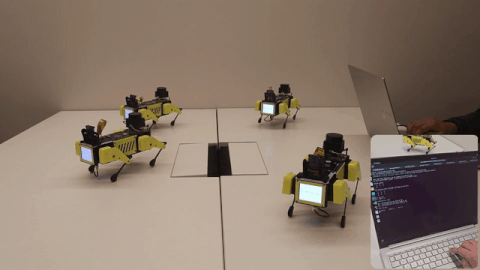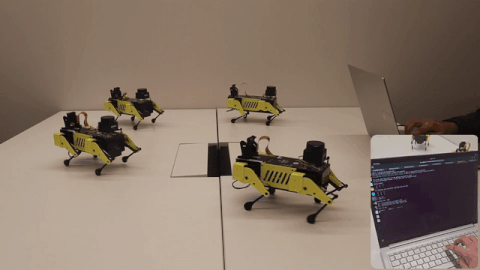
I created a fleet package that uses ROS 2 namespacing and synchronised state estimation to enable cooperative motion, shared heading control, and distributed communication.
So if you have access to multiple Mini Pupper 2 robots, try out coordinated multi-robot teleoperation.
[Demo - Fleet Coordination](https://youtu.be/Q4m8wsLZWkY)
[Code - mini\_pupper\_fleet package](https://github.com/mangdangroboticsclub/mini_pupper_ros/tree/ros2-dev/mini_pupper_fleet)
### Navigation and SLAM
If you’ve fitted your Mini Pupper 2 with a LiDAR sensor, the navigation stack now allows you to use SLAM Toolbox and Nav2 to perform reliable map-based localization and path planning. The configuration is currently tuned for table-area navigation but can be altered for other environments.
This setup enables a Mini Pupper 2 with LiDAR to perform autonomous indoor navigation and mapping.
[Demo - Navigation and SLAM](https://youtu.be/4jJ_QinYjgU)
[Code - mini\_pupper\_navigation package](https://github.com/mangdangroboticsclub/mini_pupper_ros/tree/ros2-dev/mini_pupper_navigation)
All of these developments have been pushed upstream to the [MangDang Robotics Club ROS repository](https://github.com/mangdangroboticsclub/mini_pupper_ros/tree/ros2-dev) and are available for anyone to explore with their own Mini Pupper 2.
I’d be happy to discuss implementation details or hear from others experimenting with ROS 2 on small quadruped platforms.
Best regards,
Kishan Grewal
[GitHub](https://github.com/kishan-grewal) | [LinkedIn](https://www.linkedin.com/in/kishan-grewal)
---
### Author:  [@mangdang](https://discourse.openrobotics.org/u/mangdang)
#### Post date: [November 5, 2025, 10:04am UTC](https://discourse.openrobotics.org/t/new-ros-2-features-for-mini-pupper-2/50806/2 "2025-11-05T10:04:35Z")
Great jobs! 👍

---
### Author:  [@kishan-grewal](https://discourse.openrobotics.org/u/kishan-grewal)
#### Post date: [November 5, 2025, 10:25am UTC](https://discourse.openrobotics.org/t/new-ros-2-features-for-mini-pupper-2/50806/3 "2025-11-05T10:25:30Z")
Forgot to add these!
Here’s the link to the repository, with support for ROS 2 Humble and Ubuntu 22.04:
[mini\_pupper\_ros repo](https://github.com/mangdangroboticsclub/mini_pupper_ros)
And here are some gifs to showcase the three main packages I added/worked on.
Navigation and SLAM (`nav2`, `slam_toolbox`):

YOLO Person Tracking (`rclpy`)

EKF-based Fleet Movement (`rclcpp`)
---
### Author:  [@mangdang](https://discourse.openrobotics.org/u/mangdang)
#### Post date: [November 5, 2025, 11:38am UTC](https://discourse.openrobotics.org/t/new-ros-2-features-for-mini-pupper-2/50806/4 "2025-11-05T11:38:16Z")
If you want to try on your mini pupper 2, you can download [the pre-built image](https://drive.google.com/drive/folders/1ed1lkmNPk11v3FxV_tyDyIjKIU4TWhSy?usp=sharing), thanks!
---
### Author:  [@abacula](https://discourse.openrobotics.org/u/abacula)
#### Post date: [November 6, 2025, 10:54pm UTC](https://discourse.openrobotics.org/t/new-ros-2-features-for-mini-pupper-2/50806/5 "2025-11-06T22:54:11Z")
This looks awesome! Will there ever be any Mini Pupper 2 packages released compatible with newer ROS2/Ubuntu versions?
---
### Author:  [@mangdang](https://discourse.openrobotics.org/u/mangdang)
#### Post date: [June 8, 2026, 9:51am UTC](https://discourse.openrobotics.org/t/new-ros-2-features-for-mini-pupper-2/50806/6 "2026-06-08T09:51:30Z")
Yes, sure, ROS2 Jazzy is coming!
---
### Author:  [@mangdang](https://discourse.openrobotics.org/u/mangdang)
#### Post date: [June 8, 2026, 10:35am UTC](https://discourse.openrobotics.org/t/new-ros-2-features-for-mini-pupper-2/50806/7 "2026-06-08T10:35:13Z")
@abacula **Yes! The wait is over. Mini Pupper 2 is stepping into the ROS 2 Jazzy era!** 🐶⚡
🤖 Check out this butter-smooth 2D SLAM and Navigation running flawlessly on **Ubuntu 24.04** and seamlessly matching with **Gazebo Harmonic**!
Bye Humble, you will be missed… (well, not really! 😉)
The updated codebase supporting ROS 2 Jazzy is being pushed to our repository.
👉[github.com](https://github.com/mangdangroboticsclub/mini_pupper_ros)
Let us know if you are planning to migrate your robots to Jazzy Jalisco! 🚀
* * *
[ ](https://www.youtube.com/watch?v=zl-pBIf52Tk)